移动 (Move) API
创建移动动作
curl -X POST \
  -H "Content-Type: application/json" \
  -d '{"creator": "xxx", "type": "standard" ...}' \
  http://192.168.25.25:8090/chassis/moves
返回
{
  "id": 5 // 新创建动作的 ID。
}
请求参数
interface MoveActionCreate {
  creator: string; // 动作的发起者(仅用于诊断目的)。
  type:
    | 'standard'
    | 'charge' // 前往充电桩并对接。
    | 'return_to_elevator_waiting_point'
    | 'enter_elevator'
    | 'leave_elevator' // 已废弃。请勿使用。
    | 'along_given_route' // 已废弃。请改用其他移动类型并配合 `route_coordinates`。
    | 'align_with_rack' // 钻入货架下方(以便后续顶升)。
    | 'to_unload_point' // 移动到货架卸货点(以便后续落下)。
    | 'follow_target' // 跟随移动目标。
    | 'load_onto_truck' // 将机器人载着的货架装到货车上。
    | 'unload_from_truck'; // 从货车上卸下货架。
  target_x?: number;
  target_y?: number;
  target_z?: number;
  target_ori?: number;
  target_accuracy?: number; // 单位:米(可选)。

  // 要遵循的路径。
  //
  // 大多数移动类型均支持,例如 `standard`、`charge`、`align_with_rack`。
  // 以逗号分隔的坐标列表字符串,
  // 格式为 "x1, y1, x2, y2"。
  route_coordinates?: string;

  // 沿着指定路径移动时,绕过障碍物的允许偏航距离。
  //
  // 大多数移动类型均支持,例如 `standard`、`charge`、`align_with_rack`。
  // 当指定为 0 时,机器人遇到障碍物会始终停止并等待,而不会尝试绕行。
  detour_tolerance?: number;

  // 如果为 true,当机器人进入 `target_accuracy` 半径范围内时,动作将立即成功。
  use_target_zone?: boolean = false;

  charge_retry_count?: number; // `charge` 动作失败前的重试次数。

  rack_area_id: string; // 执行点到区域或区域到区域的货物移动动作时,提供目标货架区域 ID。

  properties?: { // 可选:自 2.11.0 起支持
    inplace_rotate?: boolean; // 可选。自 2.11.0 起支持:严格原地旋转,不带任何线速度。

    // 可选。货架堆叠层数的索引。
    // 用于 type = "align_with_rack" 和 "to_unload_point"。
    rack_layer?: number;

    // 要操作的货车点位,格式为 "<货车 SN>/<点名>",
    // 例如 "PS55606h08893jr/GL"。
    // 用于 type = "load_onto_truck" 和 "unload_from_truck",这两个类型不驶向目标位姿。
    target_id?: string;
  }
}
顶升设备
自 2.7.0 起,新增了一个型号(代号为 Longjack),它可以钻入货架下方并将其顶起。
在典型的点到点任务中,机器人应使用以下命令序列来装载货物并将其卸载到另一个位置:
- 钻入货架下方:创建一个
type=align_with_rack的移动动作以钻入货架下方。 - 升起顶升设备:当移动成功时,调用
/services/jack_up。- 顶升设备的进度通过 Jack State Topic (顶升状态话题) 报告。
- 当顶升设备完全升起时,机器人的轮廓 (footprint) 将扩大以适配货架的轮廓。 更新后的轮廓可以通过 Robot Model Topic (机器人模型话题) 获取。
- 移动到卸货点:顶升设备完全升起后,创建另一个
type=to_unload_point的移动动作以移动到卸货点。 - 降下顶升设备:调用
/services/jack_down进行卸货。 - (可选)创建下一个移动动作。机器人在发起下一个动作前会先移开货架点。
| Robot Admin 截图 | 实拍图 |
|---|---|
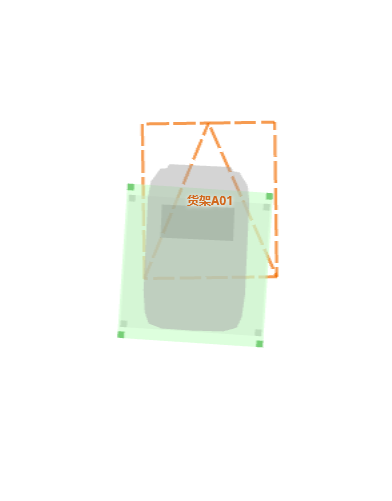 | 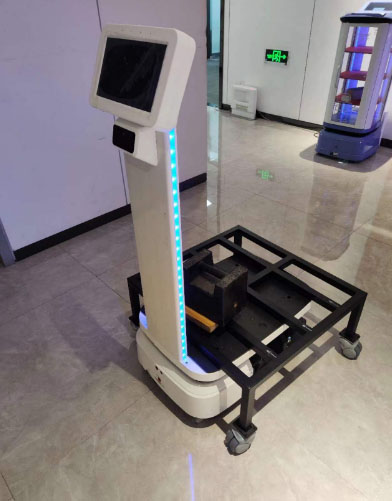 |
注意
必须正确配置某些参数才能确保安全运行。参见 rack.specs
点到区域移动
除了将货架或托盘从一个点移动到另一个点的点到点移动外,我们还支持:
- 点到区域移动:当预先不知道目标区域哪些点位是空闲时,这是最常用的移动方式。
- 区域到区域移动:用于将一个区域内的所有货架或托盘移动到另一个区域。
在建图平台上,应添加货架区域多边形。该区域内的所有货架点都被视为该组的一部分。
收到 type=to_unload_point 且 rack_area_id={SOME_ID} 的移动动作后,机器人会扫描该区域内的所有货架点,并移动到第一个空闲点位。如果所有点位都被占用,移动失败并报错 NoFreeSpaceInRackArea。
引入了几个新的失败原因,例如:
InvalidRackAreaIdInvalidRackAreaUnknownRackSpaceStateNoRackInRackAreaAlignFailedInRackAreaNoFreeSpaceInRackAreaFailedToUnloadInRackArea
区域到区域移动
创建一个 type=align_with_rack 且 rack_area_id={SOME_ID} 的移动动作;机器人会巡检源区域,找到第一个存放有货架的货架点,并与其对接。
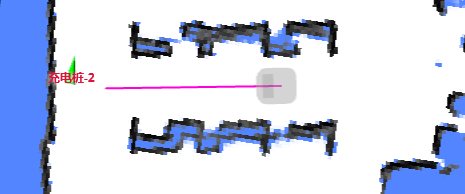
严格遵循给定路线
route_coordinates 可与大多数移动类型组合使用,例如 align_with_rack、to_unload_point。
当提供 route_coordinates 且 detour_tolerance=0 时,机器人会尽可能紧密地遵循路线,且不会尝试避障(只会停在障碍物前)。
这常用于库存盘点。
跟随目标
此动作指示机器人跟随一个移动的目标。
curl -X POST
  -H "content-type: application/json" \
  --data '{"type":"follow_target"}' \
  http://192.168.25.25:8090/chassis/moves
创建此动作后,用户应通过 WebSocket 话题 /follow_target_state 发送目标位姿:参见 Follow Target
货车装货与卸货
这两个类型用于在机器人与货车之间转运货物。货车尾部带有可升降的尾板,一个移动动作会完成整个流程: 上尾板、进入车厢、升起或降下顶升,再返回候车点。与货车的协作(例如等待尾板落地、等待尾板与车厢 持平)也由该动作内部完成,因此尾板运行期间动作会一直保持 moving 状态。
| 移动类型 | 开始时的顶升状态 | 说明 |
|---|---|---|
load_onto_truck | 升起 | 把机器人载着的货架送到货车车厢内。 |
unload_from_truck | 降下 | 从货车车厢内取出货架并带回地面。 |
机器人必须已经停在货车的候车点(地面点)上,通常由前一个 standard 移动动作送达。货车与 通道由机器人当前位姿匹配,因此机器人需在某个候车点 1.0 m、30° 以内,否则动作会立即失败并报 NotAtTruckGroundPoint。该动作不会驶向目标位姿,请通过 properties.target_id 指定货车点位 (创建请求仍需包含 target_x/target_y、target_ori 或 properties.target_id 之一):
curl -X POST \
  -H "Content-Type: application/json" \
  -d '{"creator": "xxx", "type": "load_onto_truck", "properties": {"target_id": "PS55606h08893jr/GL"}}' \
  http://192.168.25.25:8090/chassis/moves
target_id 的格式为 <货车 SN>/<点名>。货车点位不在 MapInfo 中:它们属于货车模型,并随货车的 实际停靠位置变化,因此点位 ID 需与现场货车配置一致:
| 点位 | 左通道 | 右通道 | 说明 |
|---|---|---|---|
| 候车点 | GL | GR | 机器人等待的位置,也是动作终点。 |
| 尾板点 | DL | DR | 机器人经尾板上货车的点位。 |
| 车厢货位 | L1–L3 | R1–R3 | 货车车厢内的货架位。 |
动作开始时顶升必须处于该类型要求的状态,否则动作会以 LoadInJackDownState 或 UnloadInJackUpState 失败。动作成功后,机器人回到候车点。
获取移动动作详情
curl http://192.168.25.25:8090/chassis/moves/4409
{
  "id": 4409,
  "creator": "robot-admin-web",
  "state": "cancelled",
  "type": "standard",
  "target_x": 0.7310126134385344,
  "target_y": -1.5250144001960249,
  "target_z": 0.0,
  "target_ori": null,
  "target_accuracy": null,
  "use_target_zone": null,
  "is_charging": null,
  "charge_retry_count": 0,
  "fail_reason": 0, // 参见 MoveFailReason
  "fail_reason_str": "None - None",
  "fail_message": "",
  "create_time": 1647509573,
  "last_modified_time": 1647509573
}
响应字段说明
interface MoveAction extends MoveActionCreate {
  state: "idle" | "moving" | "succeeded" | "failed" | "cancelled";
  create_time: number; // Unix 时间戳 (例如:1647509573)。
  last_modified_time: number; // Unix 时间戳 (例如:1647509573)。
  fail_reason: number; // 失败代码。仅当 state="failed" 时有效。
  // 用于调试的内部失败消息。仅当 state="failed" 时有效。
  fail_reason_str: string;
  // 用于调试的中文内部失败消息。仅当 state="failed" 时有效。
  fail_message: string;
}
移动动作列表
所有移动动作的历史记录。
curl http://192.168.25.25:8090/chassis/moves
[
  {
    "id": 4409,
    "creator": "robot-admin-web",
    "state": "cancelled",
    "type": "standard",
    "fail_reason": 0, // 参见 MoveFailReason
    "fail_reason_str": "None - None",
    "fail_message": "",
    "create_time": 1647509573,
    "last_modified_time": 1647509573
  },
  {
    "id": 4408,
    "creator": "control_unit",
    "state": "succeeded",
    "type": "none",
    "fail_reason": 0, // 参见 MoveFailReason
    "fail_reason_str": "None - None",
    "fail_message": "",
    "create_time": 1647427995,
    "last_modified_time": 1647428509
  }
]
移动状态反馈
使用 WebSocket 话题 /planning_state 接收移动状态的更新。
{
  "topic": "/planning_state",
  "move_state": "moving",
  "target_poses": [
    {
      "pos": [2.3, 20.82],
      "ori": 0
    }
  ],
  "charger_pose": {
    "pos": [0, 0],
    "ori": 0
  },
  "going_back_to_charger": false,
  "action_id": 4410, // 当前正在执行(或最后一次)移动动作的 ID。
  "fail_reason": 0, // 参见 MoveFailReason
  "fail_reason_str": "none",
  "remaining_distance": 3.546117067337036,
  "move_intent": "none",
  "intent_target_pose": {
    "pos": [0, 0],
    "ori": 0
  },
  "stuck_state": "none"
}
取消当前移动动作
curl -X PATCH \
  -H "Content-Type: application/json" \
  -d '{state: "cancelled"}' \
  http://192.168.25.25:8090/chassis/moves/current
{ "state": "cancelled" }
移动失败原因
fail_reason 字段是一个数字代码,指示移动动作失败的原因。
enum MoveFailReason {
  none = 0, // 无
  unknown = 1, // 未知原因
  GetMapFailed = 2, // 获取地图失败 (WorldMap)
  StartingPointOutOfMap = 3, // 起点在地图外
  EndingPointOutOfMap = 4, // 终点在地图外
  StartingPointNotInGround = 5, // 起点不在可行驶区域
  EndingPointNotInGround = 6, // 终点不在可行驶区域
  StartingEqualEnding = 7, // 起点和终点相同
  CalculateGlobalPathExtendedDataError = 8, // 计算全局路径扩展数据失败
  CalculationFailed = 9, // 道路不通
  CalculationTimeout = 10, // 计算超时
  NoGlobalPath = 11, // 无可用全局路径
  NotGrabStartIndexOnGlobalPath = 12, // 未能在全局路径上抓取起点
  NotGrabEndIndexOnGlobalPath = 13, // 未能在全局路径上抓取终点
  PlanningTimeout = 14, // 路径规划长时间不成功
  MoveTimeout = 15, // 路径规划成功,移动超时
  ControlCostmapError = 16, // 局部避障地图数据错误,传感器数据异常
  PowerCableConnected = 17, // 当前正连接线缆充电
  RotateTimeout = 18, // 旋转超时
  ChargeRetryCountExceeded = 100, // 充电重试次数超限
  ChargeDockDetectionError = 101, // 充电桩检测错误
  ChargeDockSignalError = 102, // 未收到充电桩对接成功信号
  InvalidChargeDock = 103, // 充电桩位置无效
  AlreadyInCharging = 104, // 当前已在充电中
  NoChargeCurrent = 105, // 接触后长时间未收到充电电流
  InvalidCabinetPos = 200, // 柜体位置无效
  CabinetDetectionError = 201, // 柜体检测错误
  NoDockWithConveyer = 202, // 当前未与接驳线对接
  NoApproachConveyer = 203, // 当前未靠近接驳线
  ElevatorPointOccupied = 300, // 电梯点被占用
  ElevatorClosed = 301, // 电梯已关闭
  ElevatorPointObscuredTimeout = 302, // 电梯点长时间被遮挡
  ElevatorPointOccupancyDetectionTimeout = 303, // 电梯点占用检测超时
  ElevatorEnterProgressUpdateTimeout = 304, // 进电梯进度更新超时
  InvalidTrackPoints = 400, // 轨迹点无效(输入坐标数不是偶数或轨迹点数 < 2)
  TooFarFromStartOfTrack = 401, // 距离轨迹起点太远
  InvalidRackDetectionPos = 500, // 货架检测点无效
  RackDetectionError = 501, // 货架检测错误
  RackRetryCountExceeded = 502, // 对接重试次数超限
  UnloadPointOccupied = 503, // 卸货点被占用
  UnloadPointUnreachable = 504, // 卸货点不可达
  RackMoved = 505, // 货架发生了明显移动
  JackInUpState = 506, // 顶升处于升起状态
  InvalidRackAreaId = 507, // 货架区域 ID 无效
  InvalidRackArea = 508, // 货架区域无效(无货架位)
  UnknownRackSpaceState = 509, // 货架空间状态未知
  NoRackInRackArea = 510, // 货架区域内无货架
  AlignFailedInRackArea = 511, // 在有货架的区域内对接失败
  NoFreeSpaceInRackArea = 512, // 货架区域内无空闲空间
  FailedToUnloadInRackArea = 513, // 在有空闲货架位的区域内卸货失败
  FollowFailed = 600, // 跟随目标丢失
  PoiDetectionError = 700, // POI 检测错误
  PoiUnreachable = 701, // POI 不可达
  BarcodeDetectionError = 702, // 条码检测错误
  NotAtTruckGroundPoint = 800, // 不在货车候车点
  LiftgateWaitTimeout = 801, // 等待货车尾板超时
  JackOperationFailed = 802, // 顶升升降失败或超时
  LoadInJackDownState = 803, // 卡车装货时顶升处于降下状态
  UnloadInJackUpState = 804, // 卡车卸货时顶升处于升起状态
  PlatformAlertError = 1000, // 系统异常
  ServiceCallError = 1001, // 服务调用错误 (restapi 使用层)
  InternalError = 1002, // 内部 ASSERT 错误
  MapChanged = 1003, // 任务执行期间地图发生变化或被清除
  MoveActionTypeDeprecated = 1004, // 接口已废弃
}
更及时的版本请访问 此 URL。